Method and apparatus for generating and tracing cleaning trajectory of home cleaning robot
US-7860608-B2Abstract
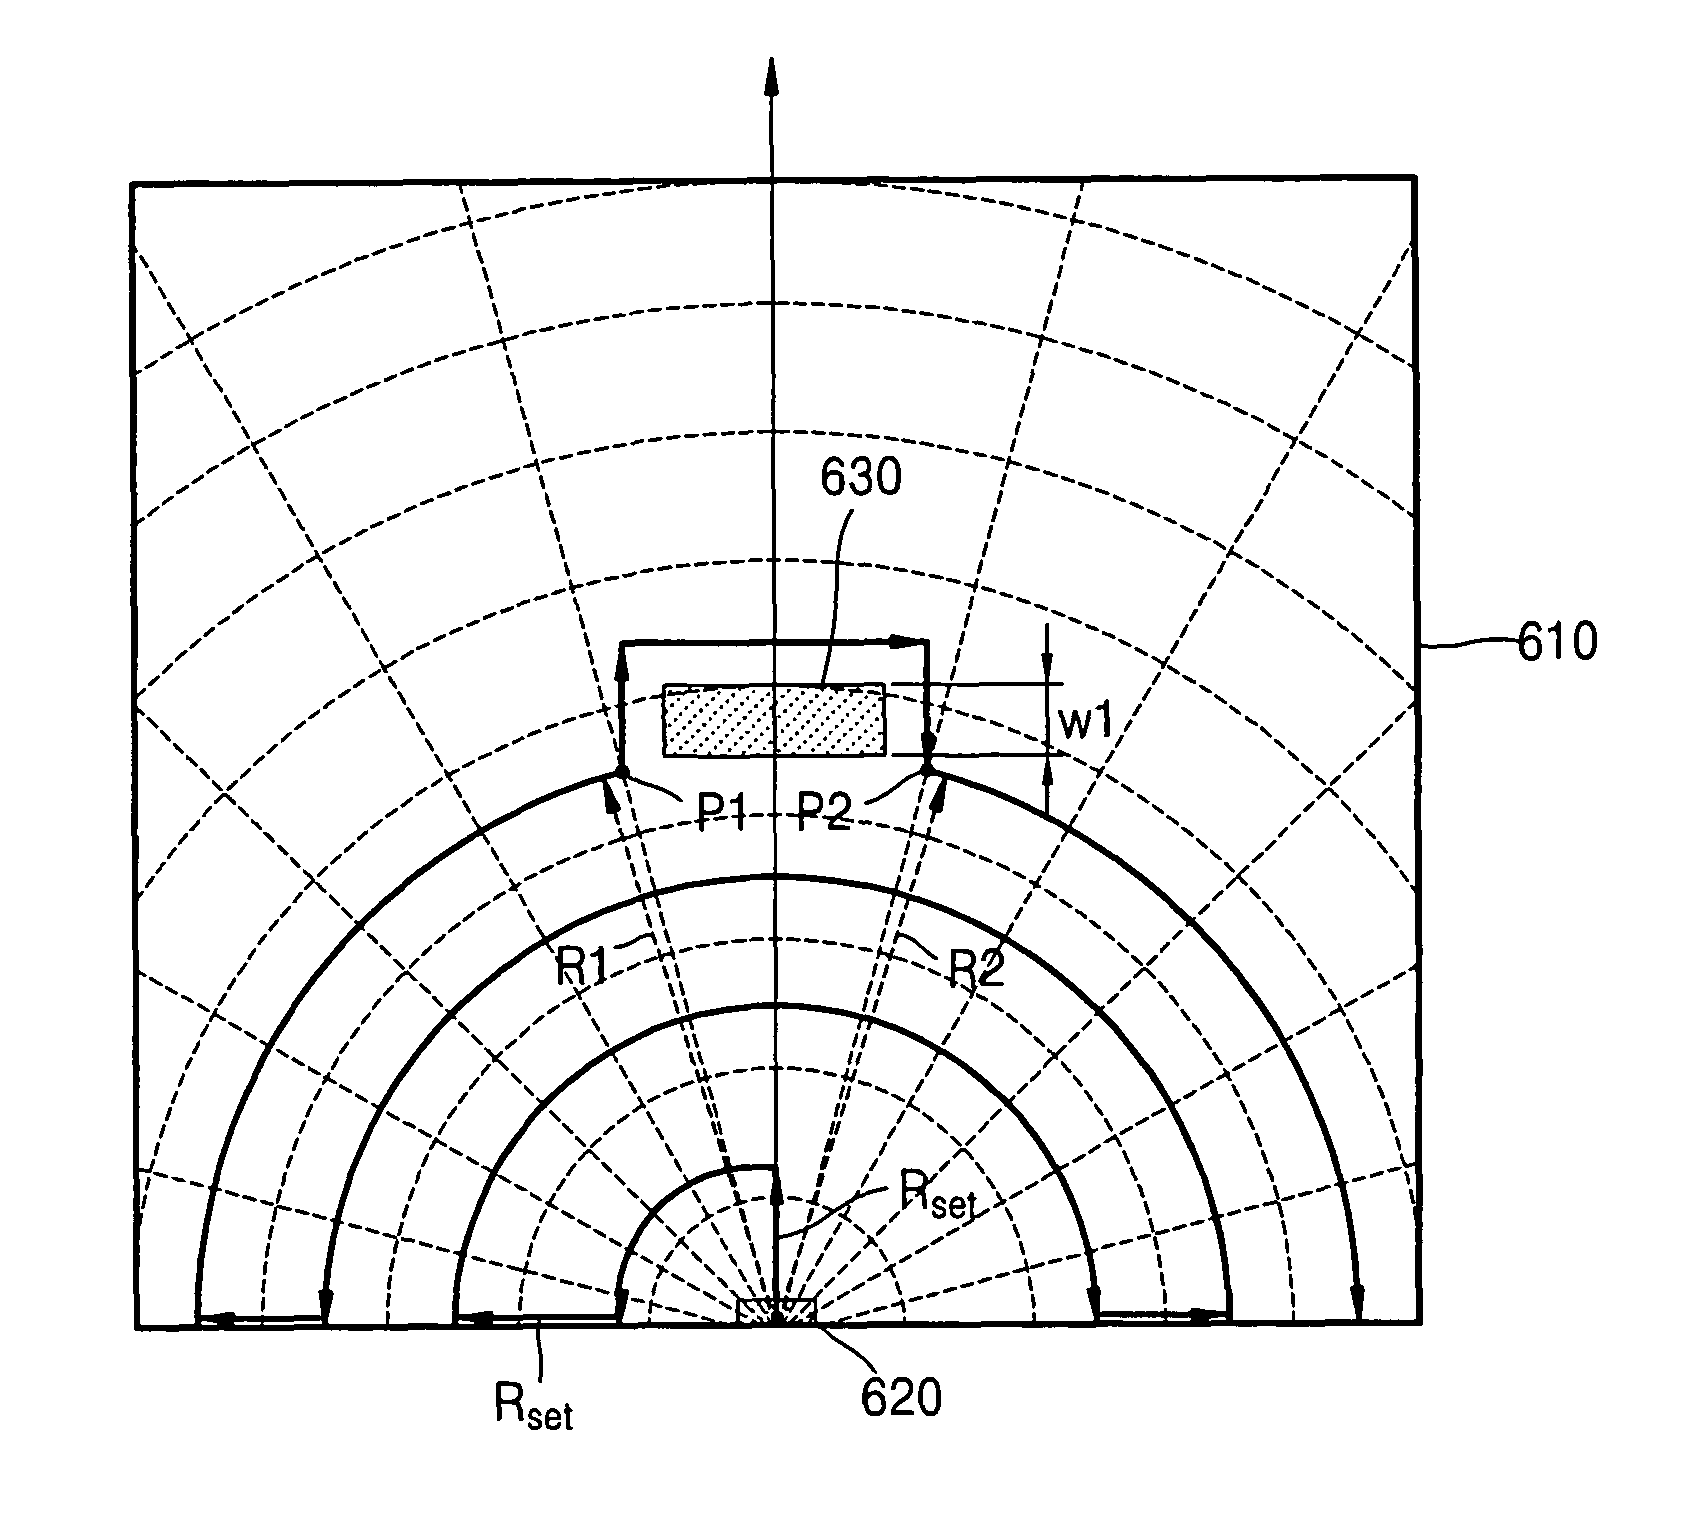
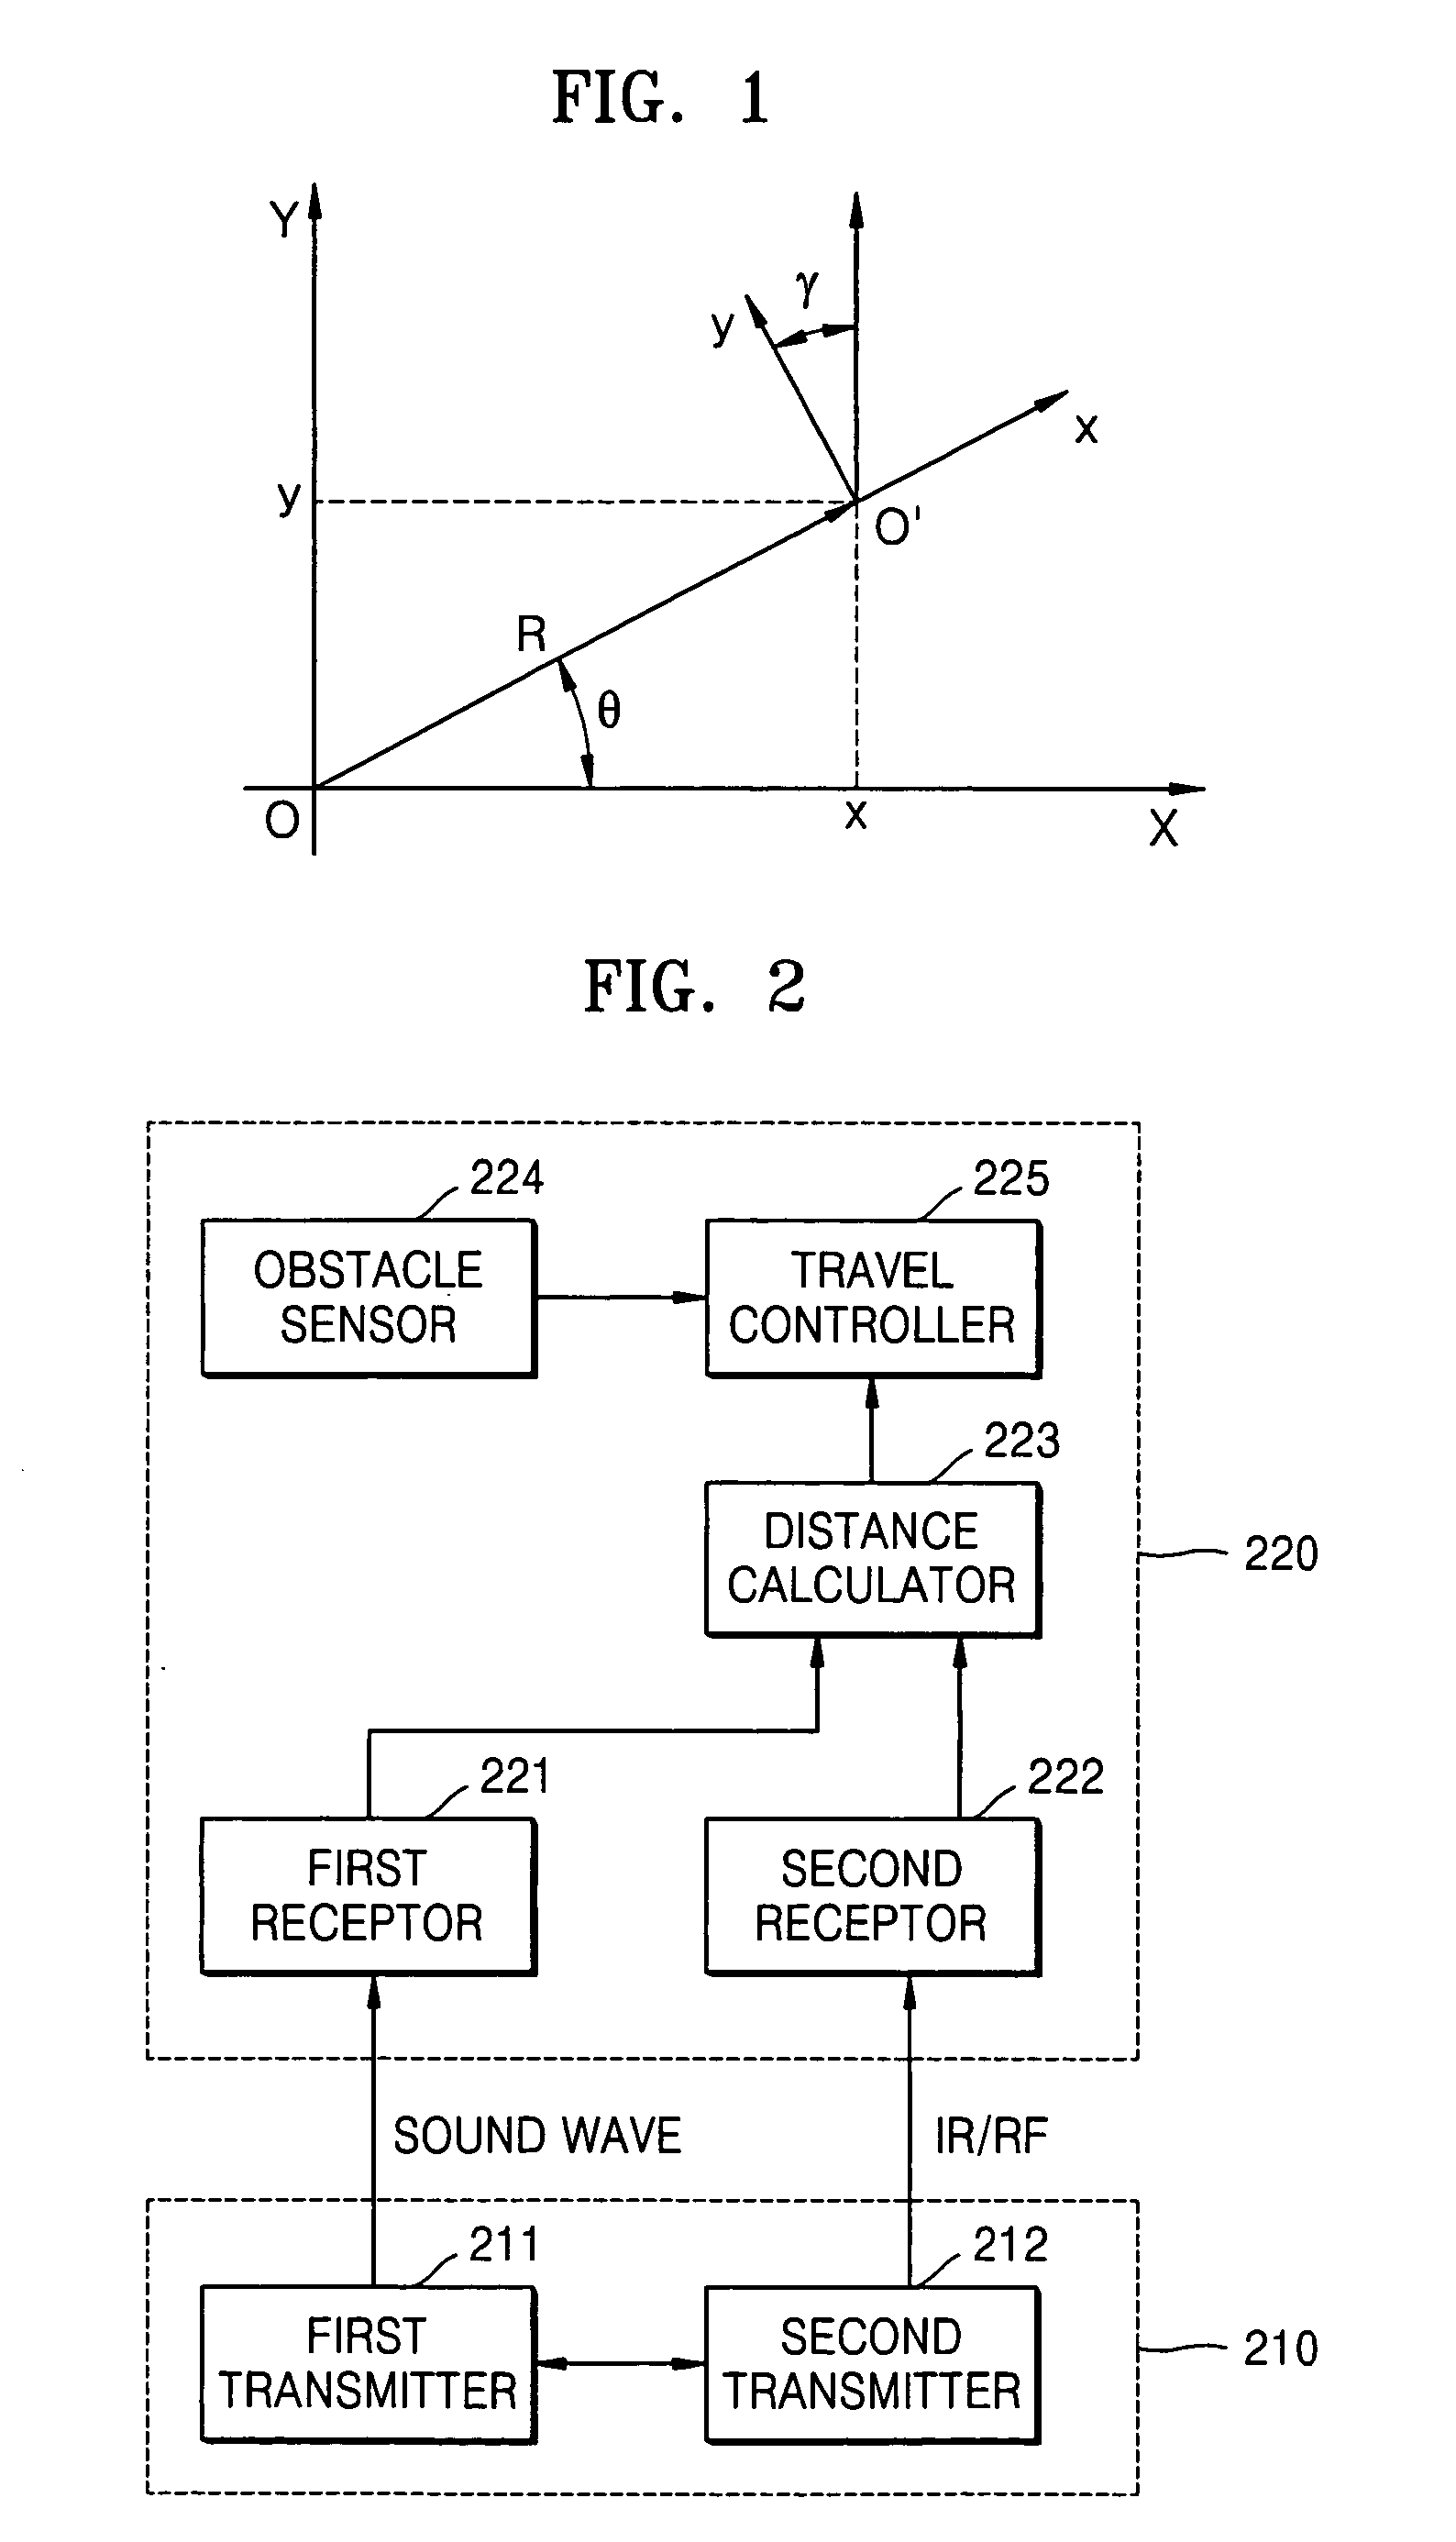
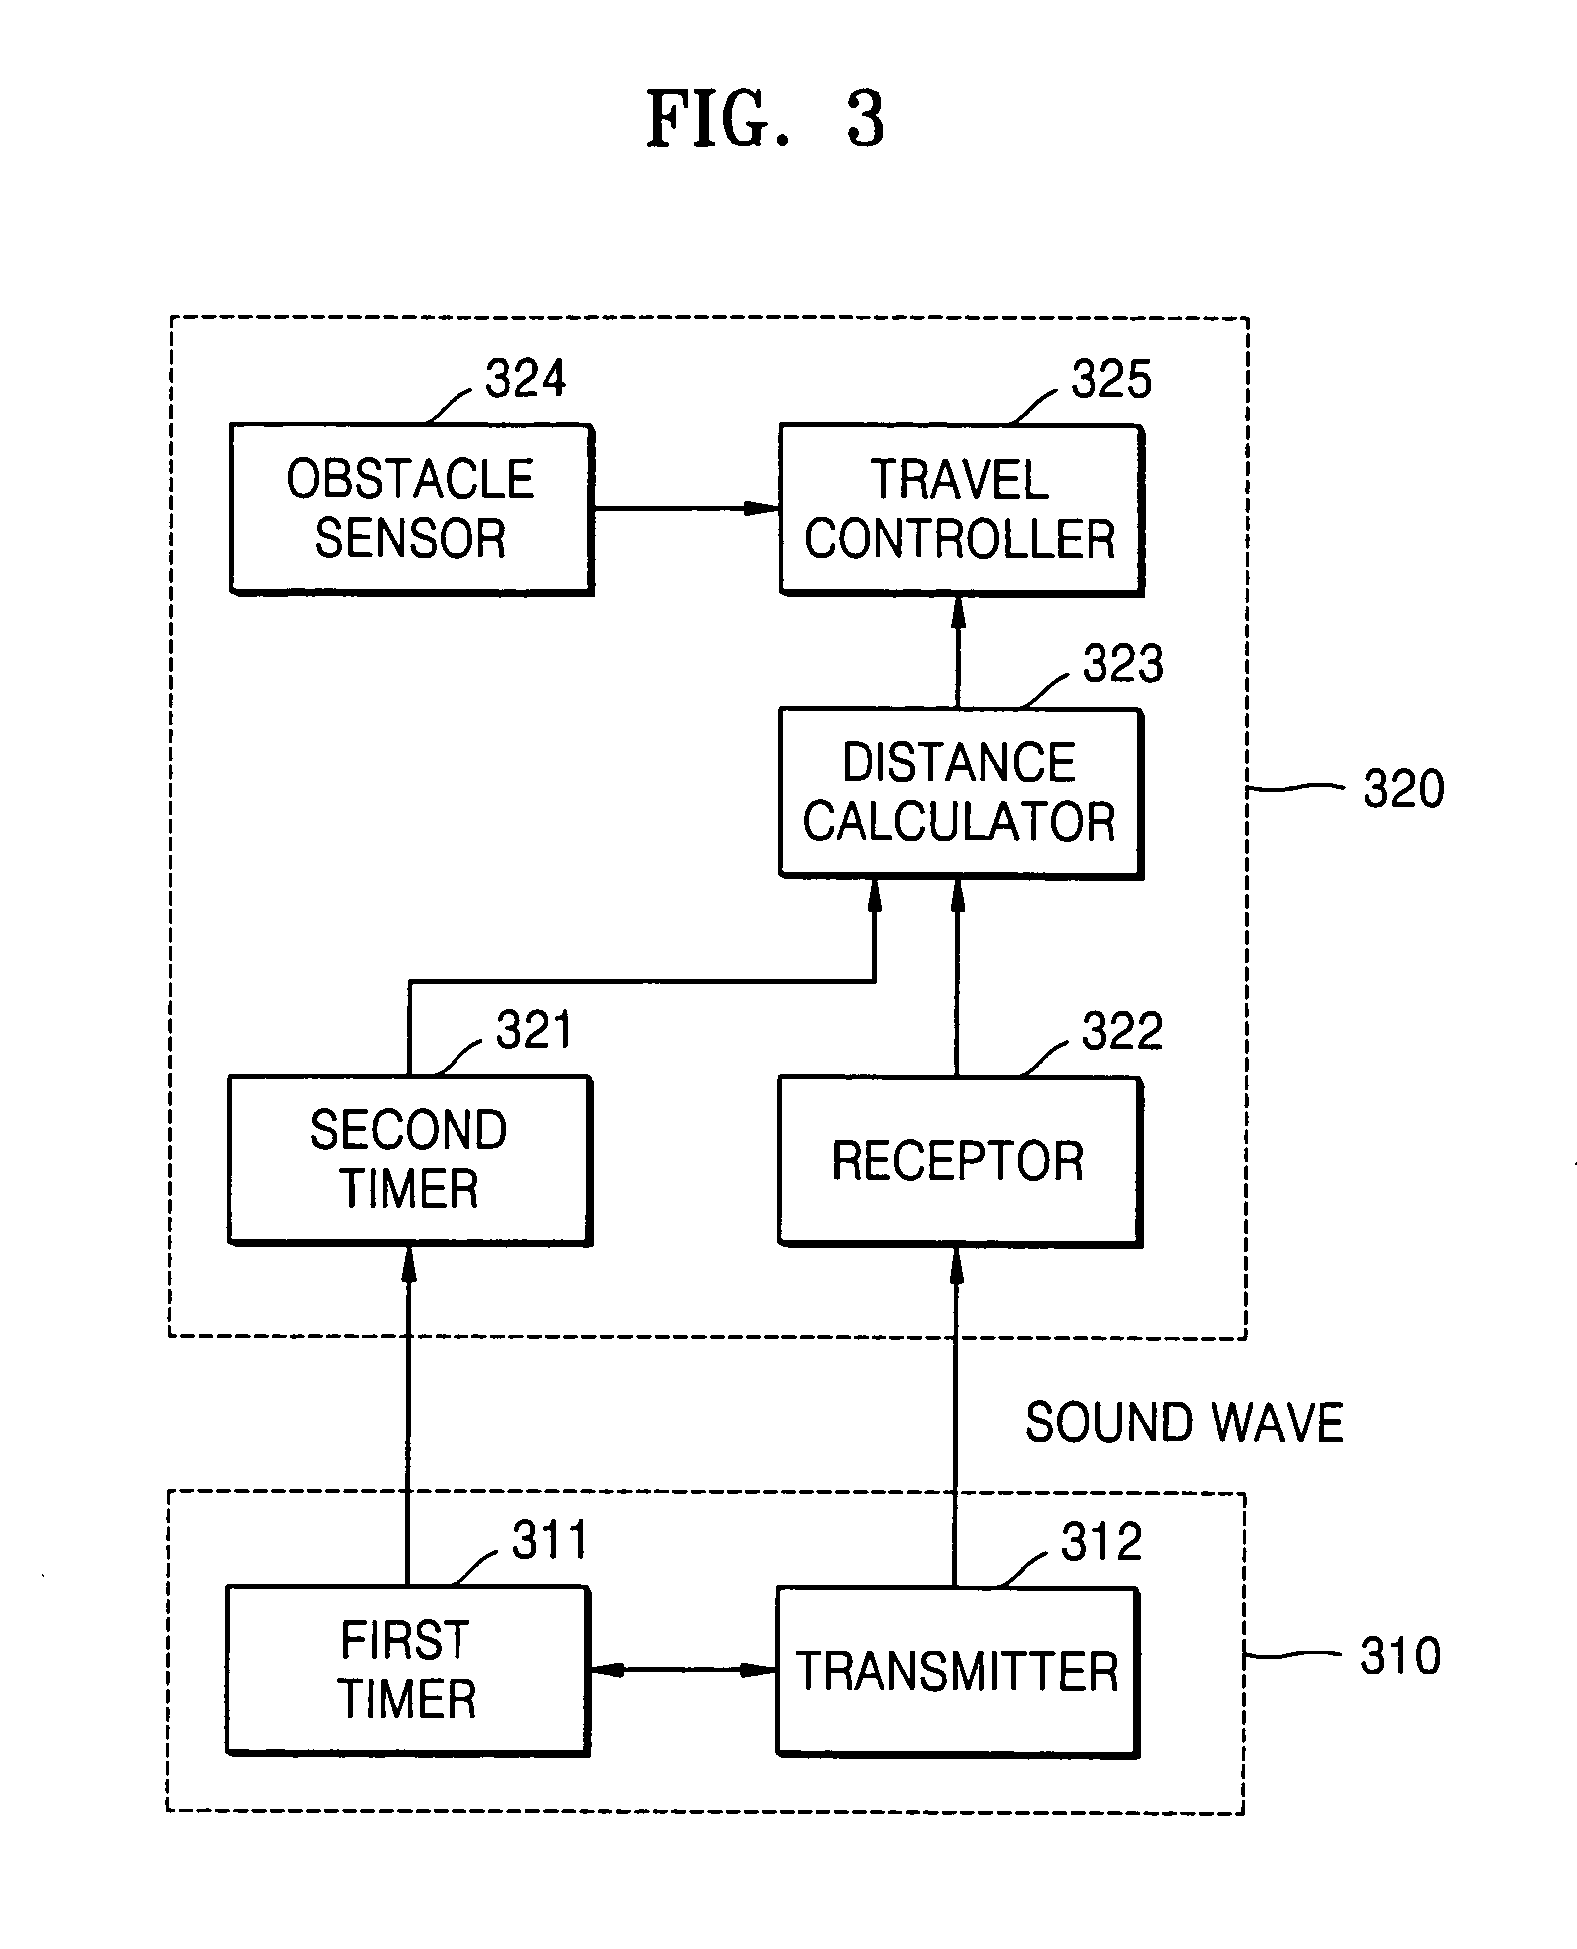
A method and apparatus generating and tracing a cleaning trajectory of a home cleaning robot the method including: controlling the home cleaning robot to straightly travel as much as a set distance from the docking station and then rotationally travel, maintaining the set distance from the docking station, until the home cleaning robot reaches one of two walls; controlling the home cleaning robot to travel as much as the set distance along the wall if the home cleaning robot reaches the wall and resume rotational-traveling around the docking station, maintaining a distance between the docking station and the home cleaning robot increased by the set distance until it reaches one of the two walls; and repeatedly controlling the home cleaning robot to travel as much as the set distance along the wall if the home cleaning robot reaches the wall and resume rotational-traveling around the docking station, maintaining a distance between the docking station and the home cleaning robot increased by the set distance until it reaches one of the two walls until the home cleaning robot arrives at a point where it cannot travel in a direction in which a distance between the docking station and the home cleaning robot increases.
Patent figures(8)
Source status & events
No source-status events are recorded.