来源记录显示 Expired
生成和跟踪家庭清洁机器人清洁轨迹的方法和装置
Method and apparatus for generating and tracing cleaning trajectory of home cleaning robot
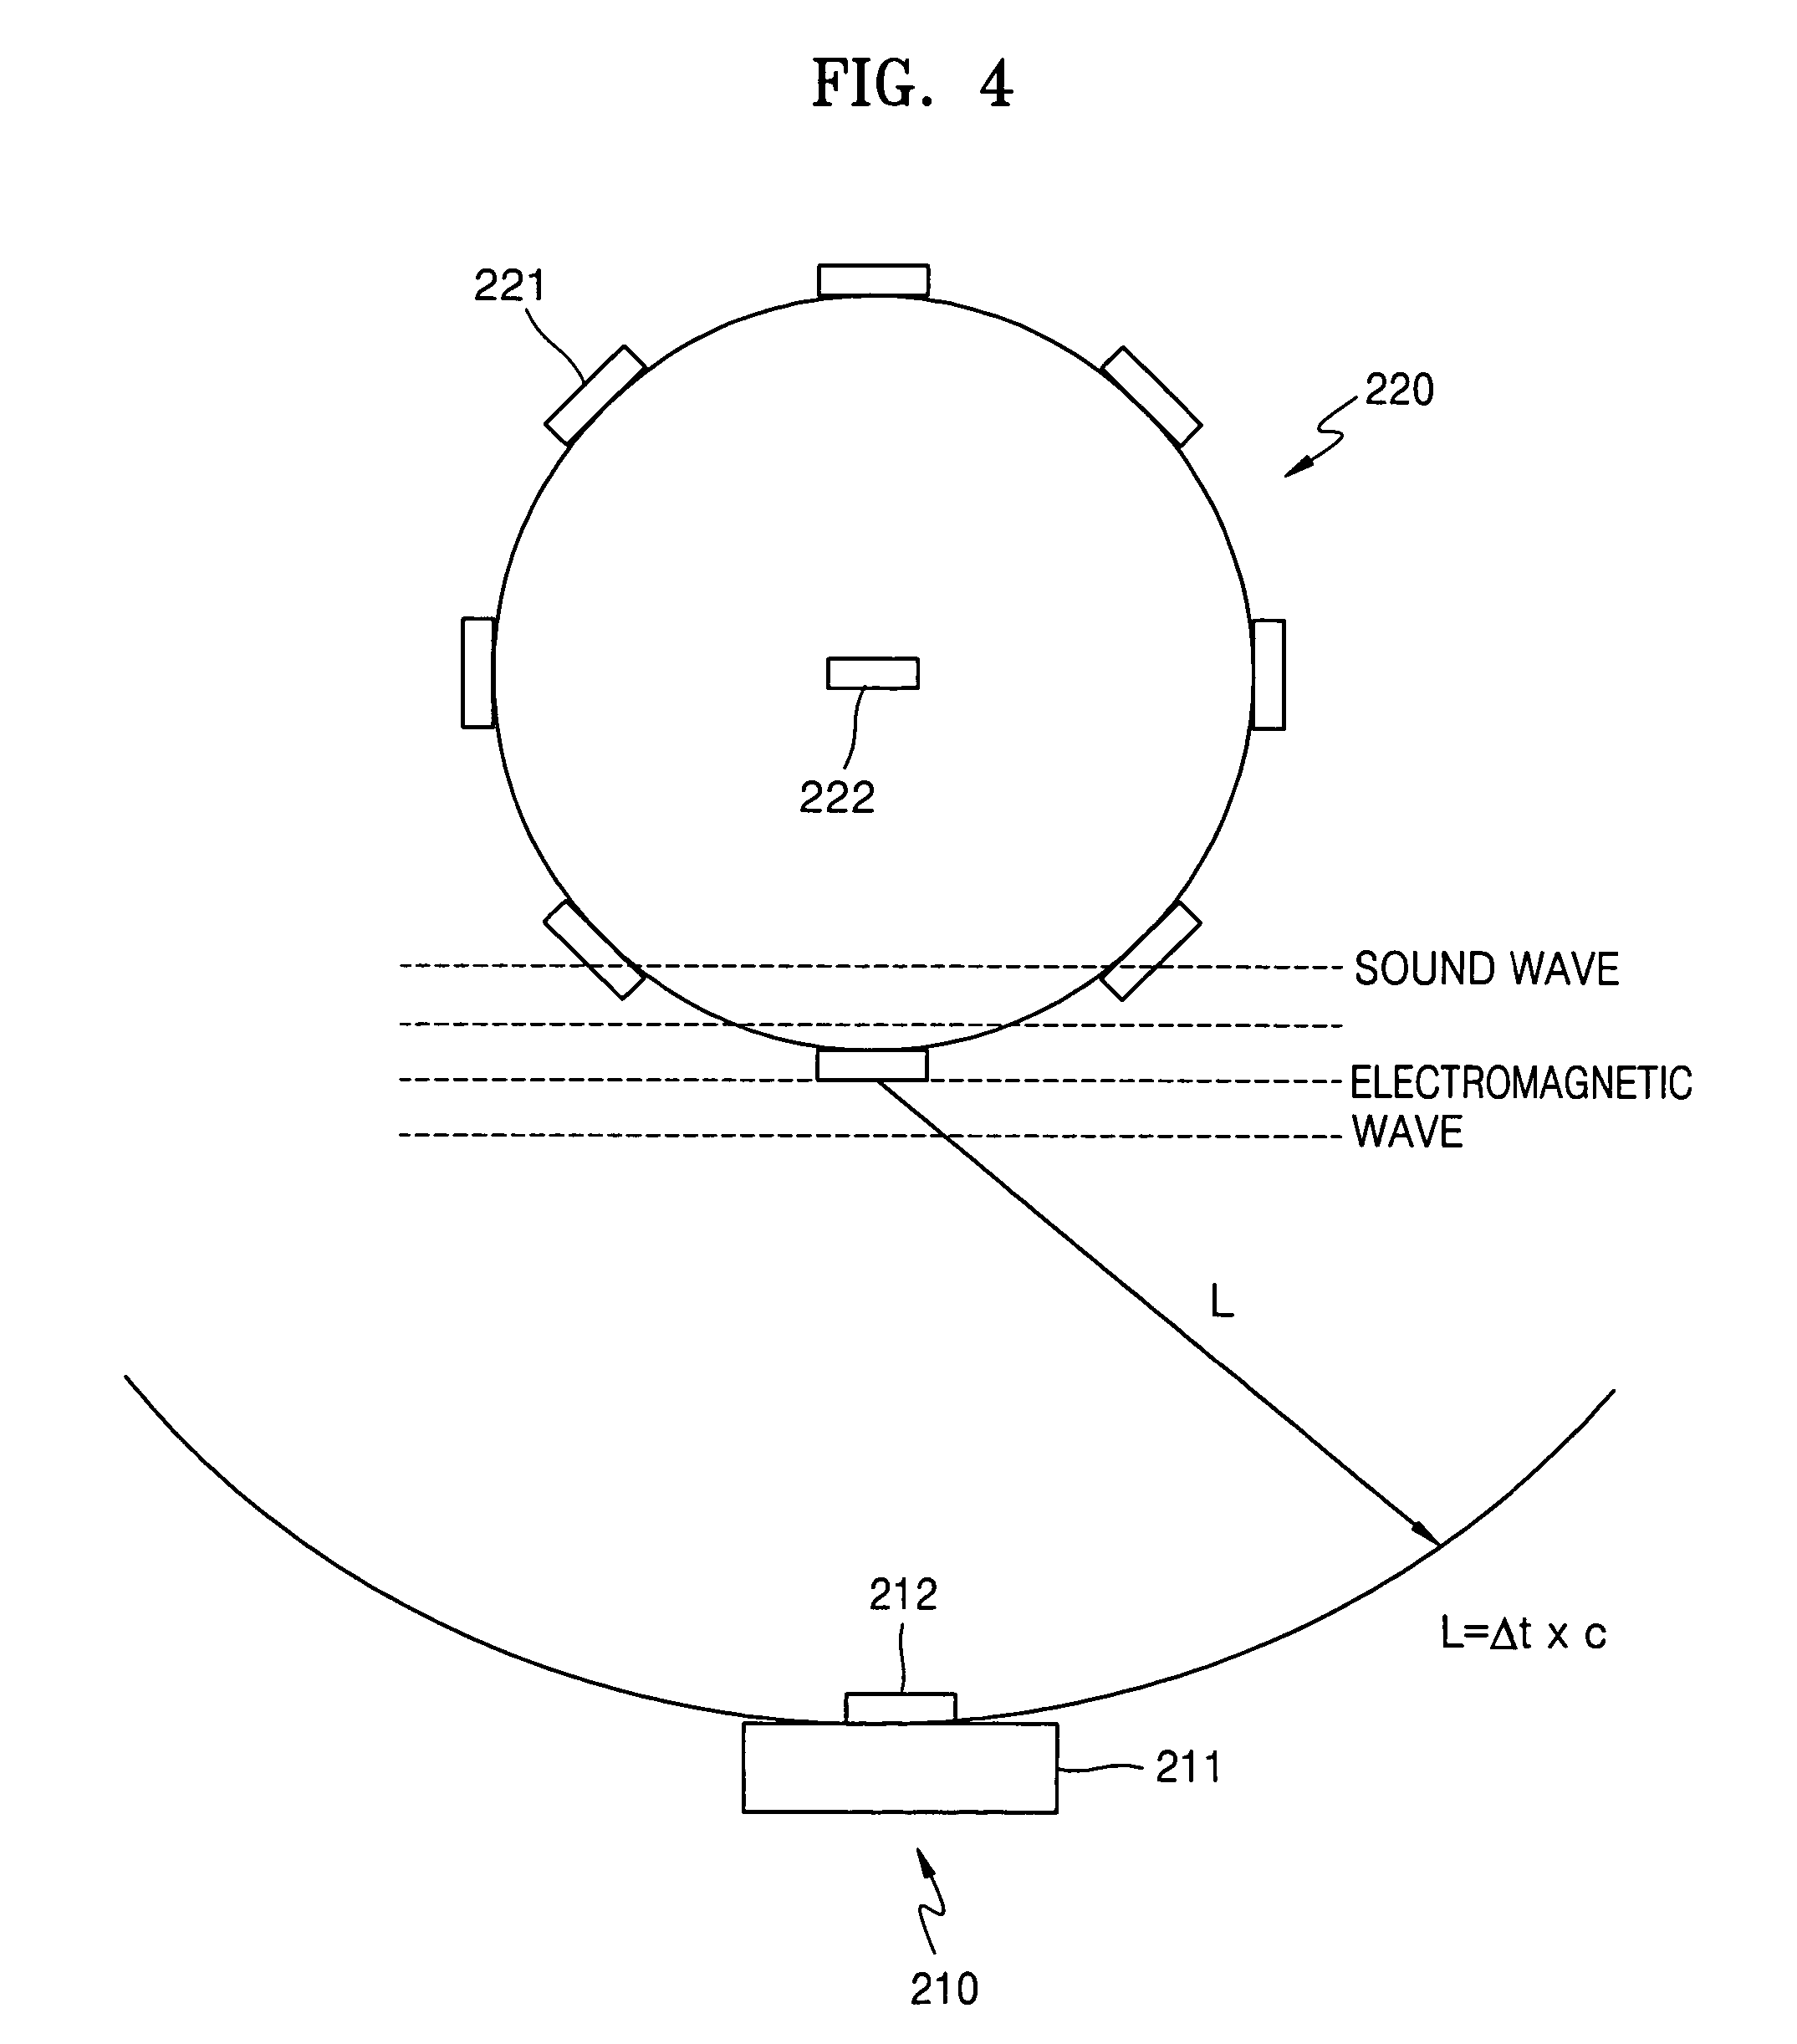
US-7860608-B2用于规划家庭清洁机器人的清洁路径。
专利摘要
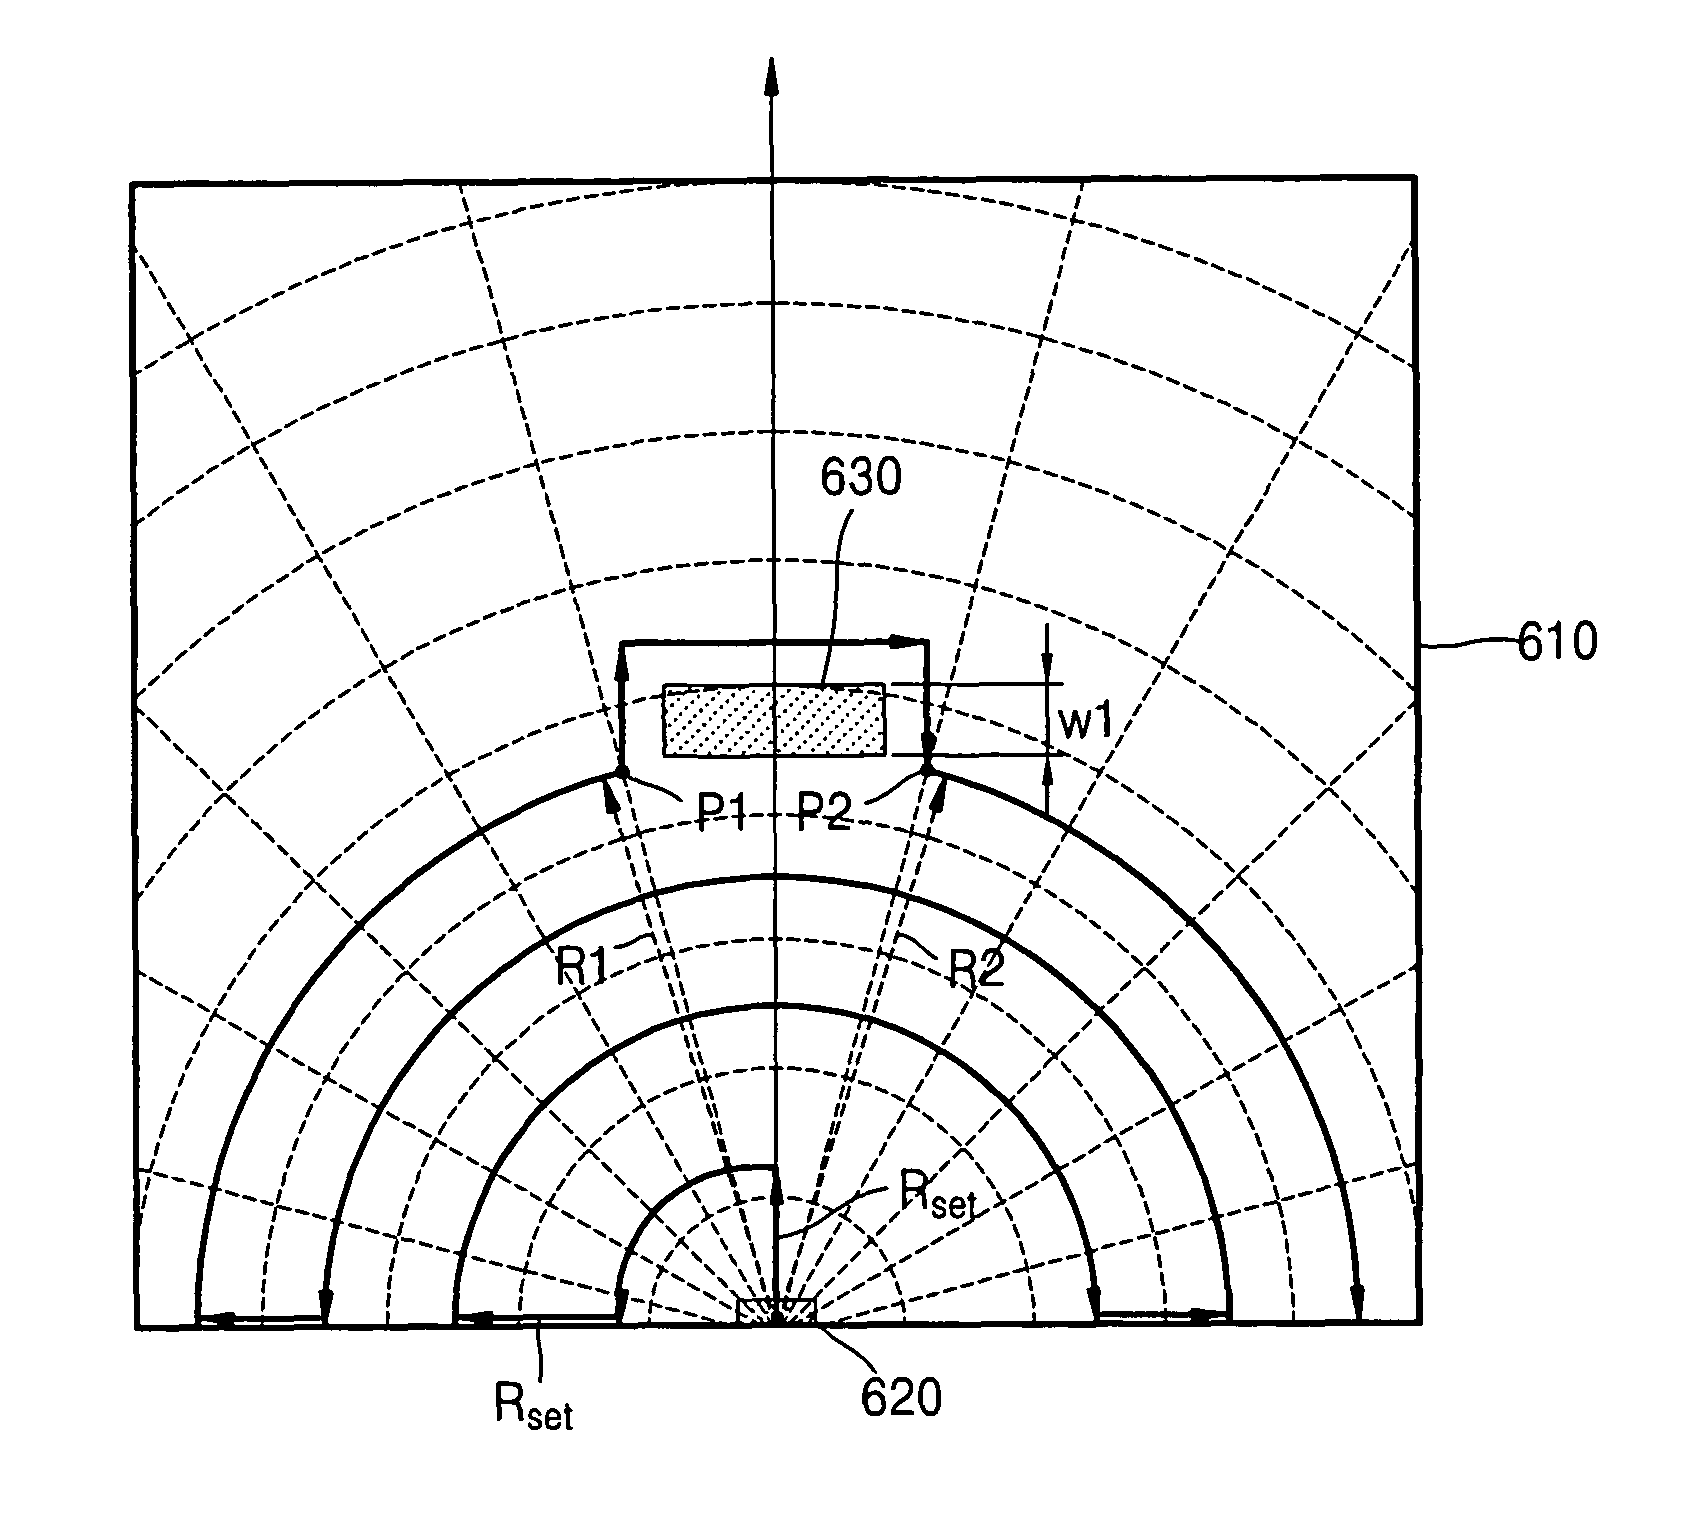
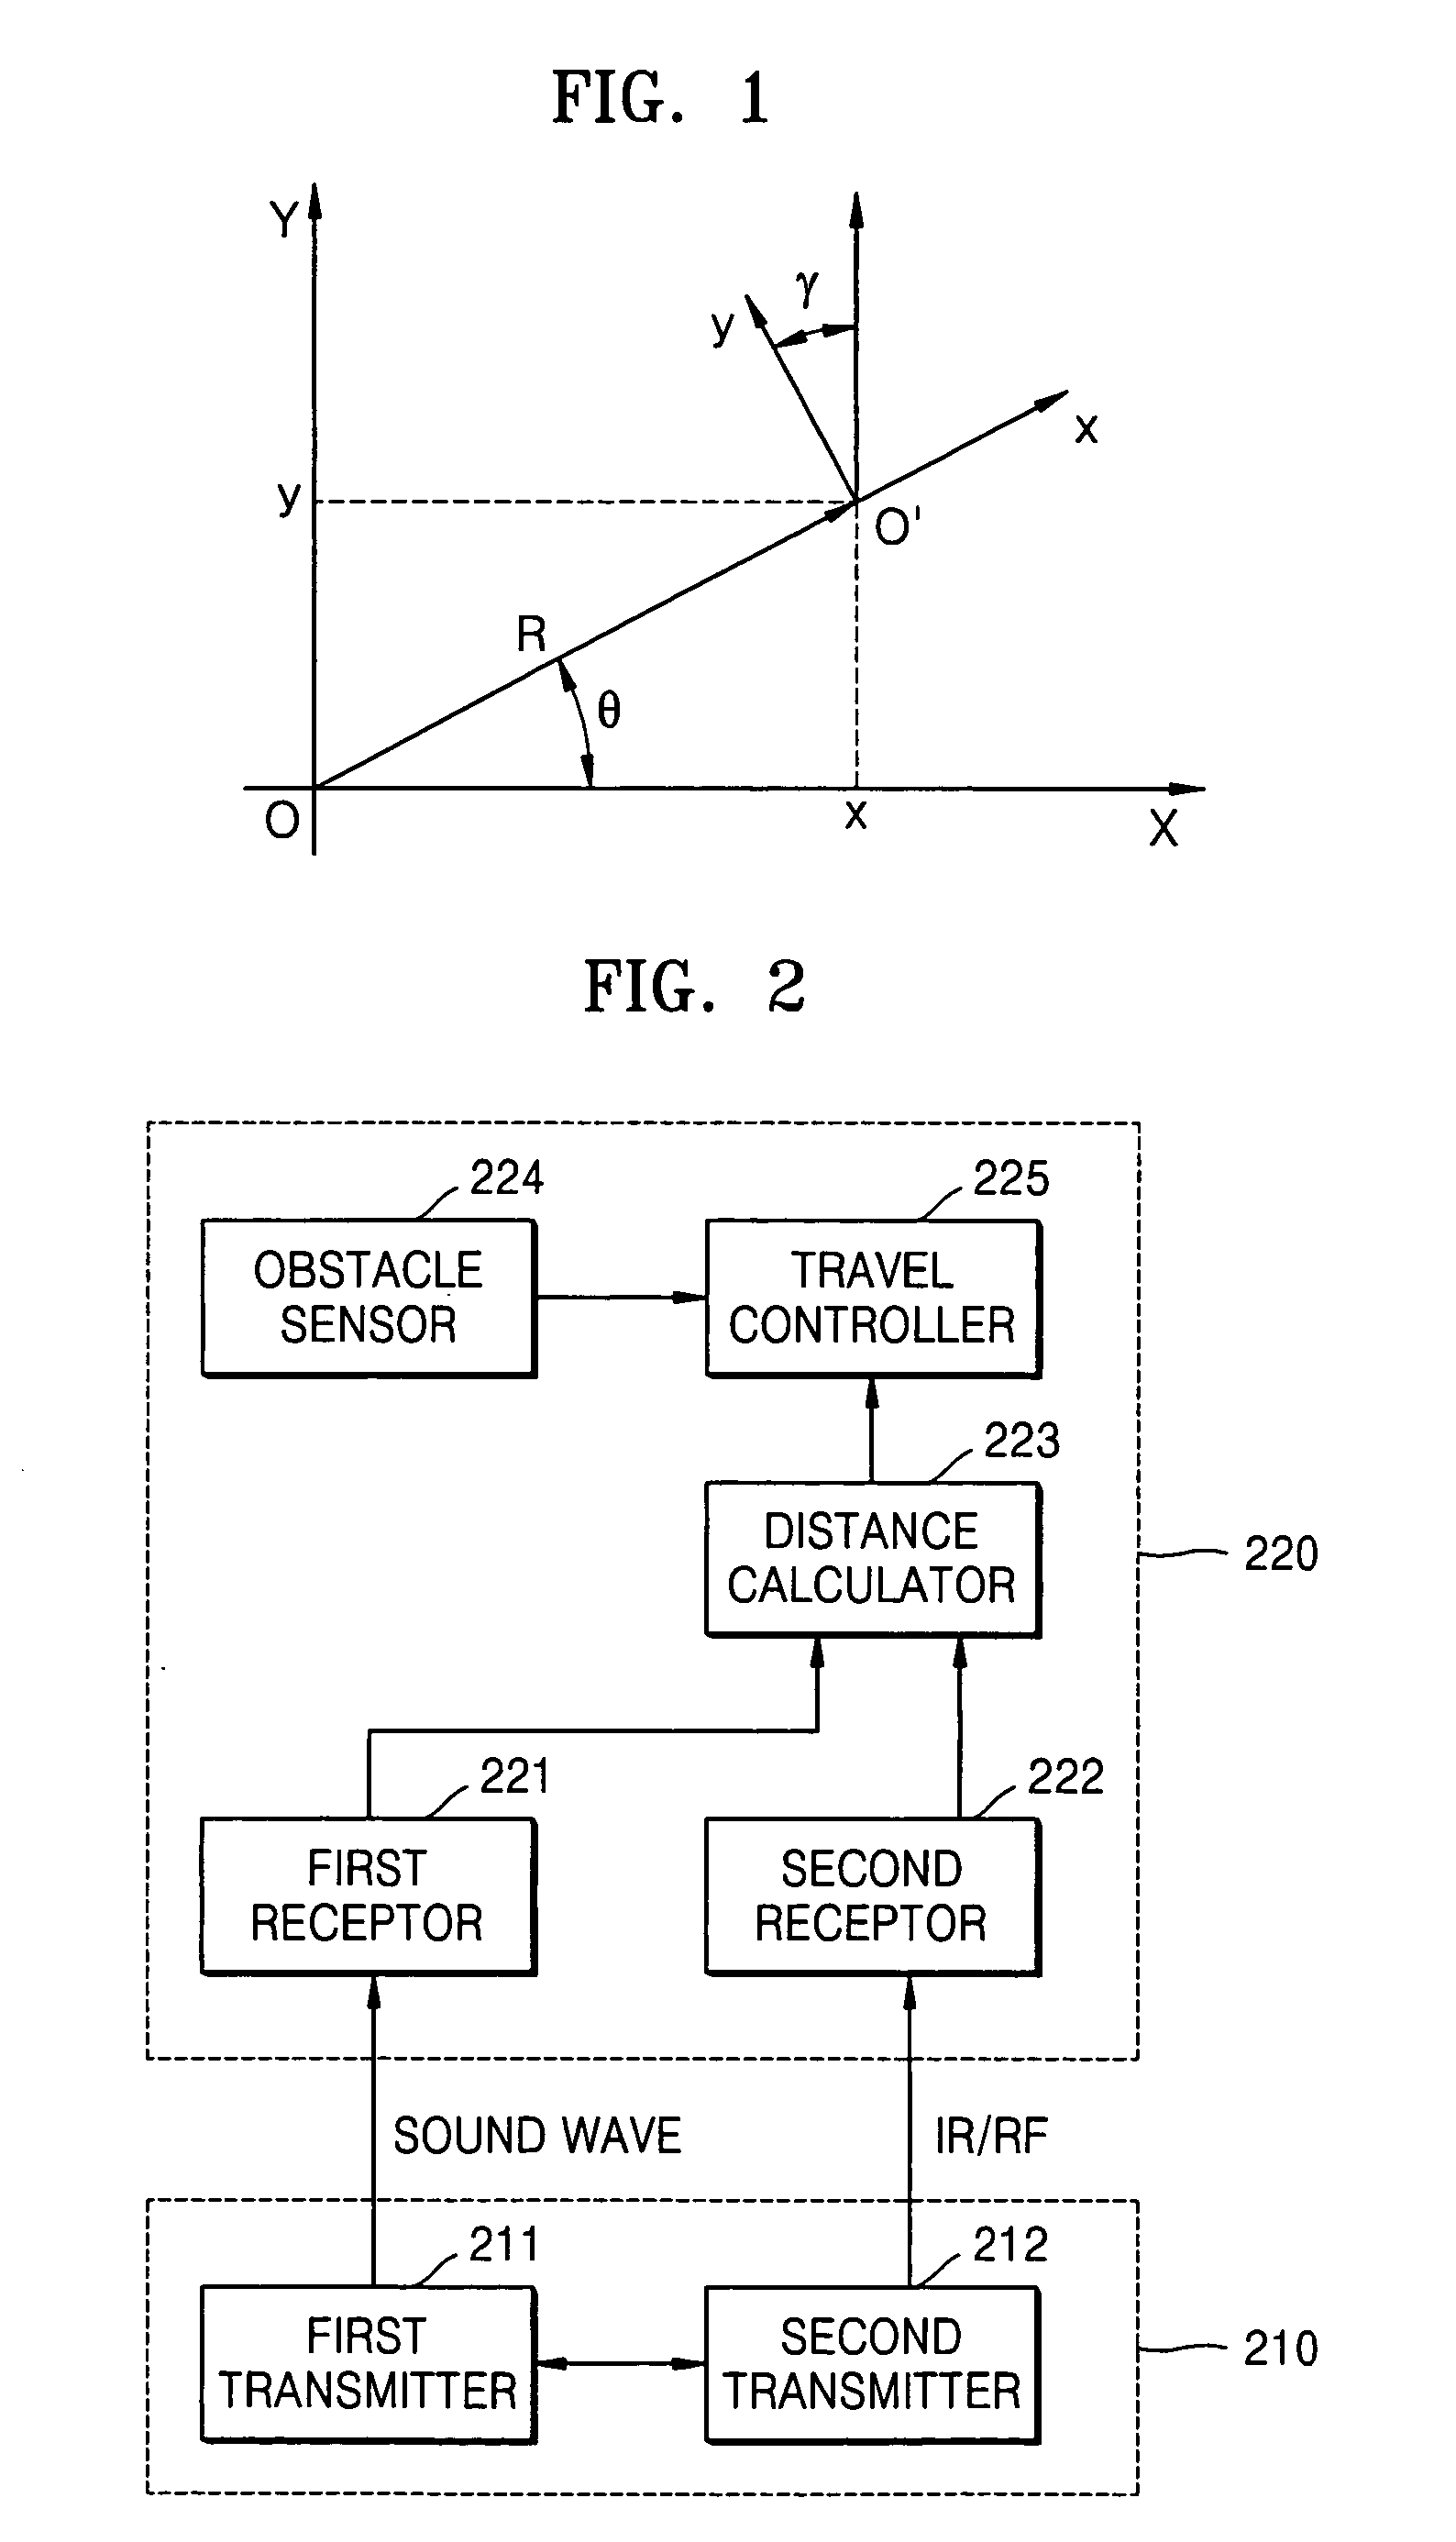
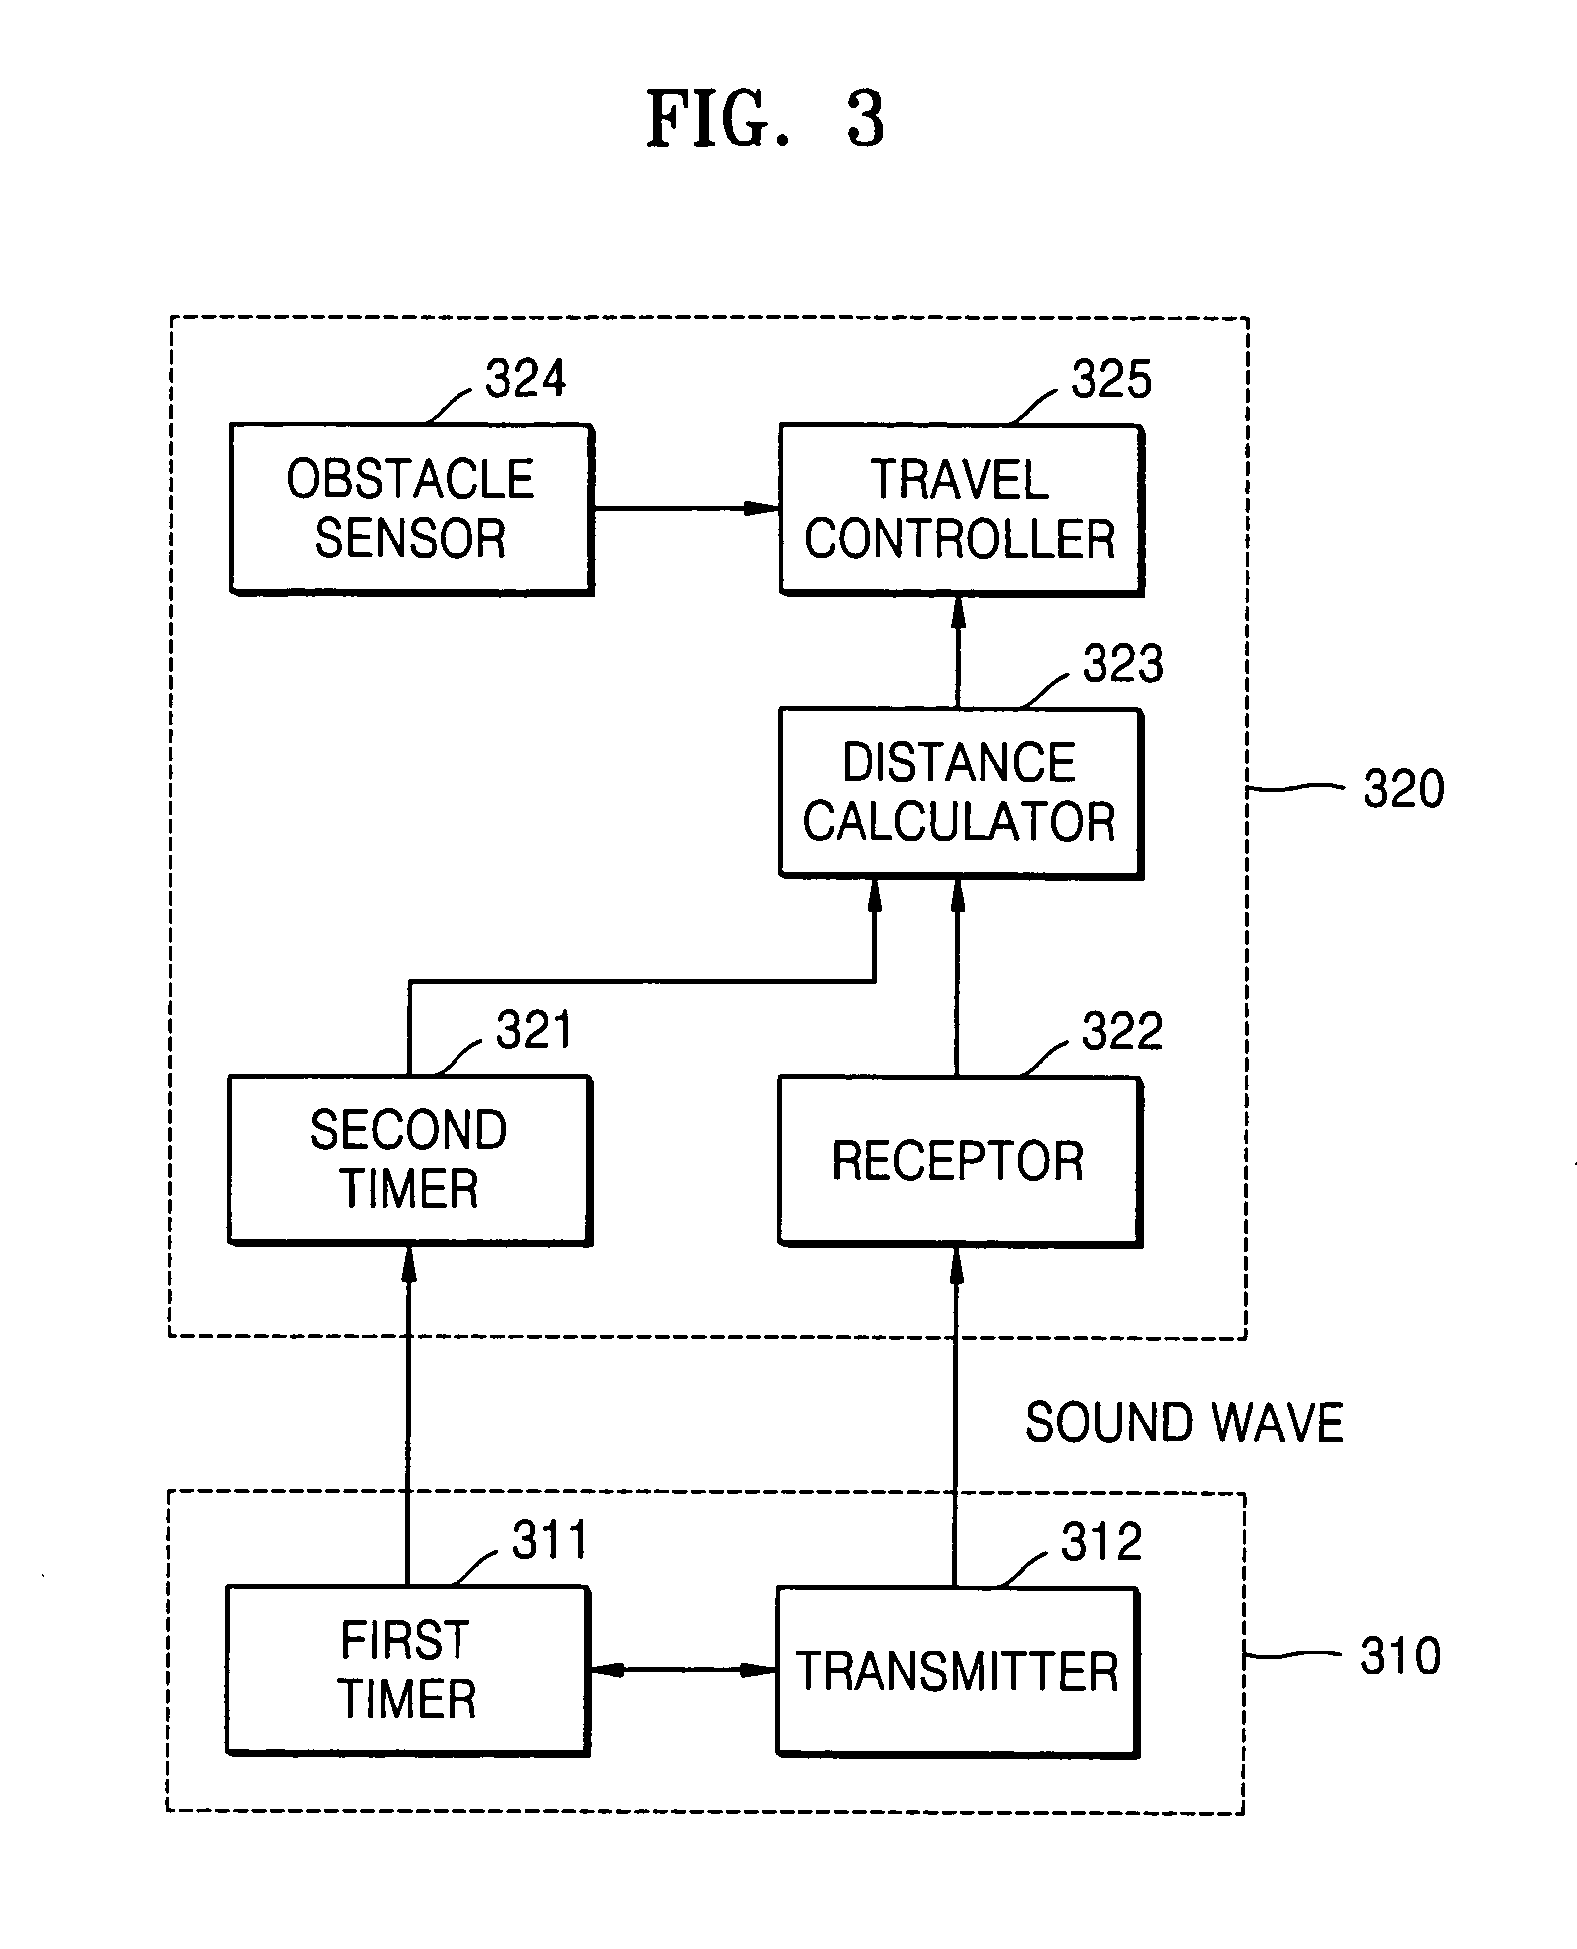
一种生成和跟踪家庭清洁机器人清洁轨迹的方法和装置,该方法包括:控制家庭清洁机器人从对接站直线行进设定距离,然后旋转行进,保持与对接站的设定距离,直到家庭清洁机器人到达两个墙壁之一;如果家庭清洁机器人到达墙壁,则控制其沿墙壁行进设定距离,并恢复围绕对接站的旋转行进,保持对接站与家庭清洁机器人之间的距离增加设定距离,直到其到达两个墙壁之一;以及重复控制家庭清洁机器人,如果其到达墙壁,则沿墙壁行进设定距离,并恢复围绕对接站的旋转行进,保持对接站与家庭清洁机器人之间的距离增加设定距离,直到其到达两个墙壁之一,直到家庭清洁机器人到达其无法在对接站与家庭清洁机器人之间的距离增加的方向上行进的点。
Original abstractA method and apparatus generating and tracing a cleaning trajectory of a home cleaning robot the method including: controlling the home cleaning robot to straightly travel as much as a set distance from the docking station and then rotationally travel, maintaining the set distance from the docking station, until the home cleaning robot reaches one of two walls; controlling the home cleaning robot to travel as much as the set distance along the wall if the home cleaning robot reaches the wall and resume rotational-traveling around the docking station, maintaining a distance between the docking station and the home cleaning robot increased by the set distance until it reaches one of the two walls; and repeatedly controlling the home cleaning robot to travel as much as the set distance along the wall if the home cleaning robot reaches the wall and resume rotational-traveling around the docking station, maintaining a distance between the docking station and the home cleaning robot increased by the set distance until it reaches one of the two walls until the home cleaning robot arrives at a point where it cannot travel in a direction in which a distance between the docking station and the home cleaning robot increases.
专利附图(8)
来源状态与事件
暂无可展示的状态事件记录。
相关专利(同品类)
使用须知
本页提供信息参考,不构成法律意见
来源状态不是法律结论专利状态可能因补缴、恢复、同族权利或地域差异而变化,应以当前权威记录和专业判断为准。
实施前应完成 FTO 评估任何生产、进口或销售决策前,应委托专利代理人或律师完成自由实施检索与侵权分析。